Edge
On the device
Scored where the sensor is, in under 3 ms per window, with no connectivity and no round trip. The answer arrives while there is still time to use it.
BADAS 2.0 is a world model for things in motion. Give it an ego scene and it returns what is about to happen: how likely a collision is over the seconds ahead, scored continuously, and a map of what the model was looking at when it decided. It is not a driver-assistance feature. It is the prediction layer that features get built on.
One forward pass produces what AV programs, fleets and ADAS integrations need, on any device with a video sensor.
Scored where the sensor is, in under 3 ms per window, with no connectivity and no round trip. The answer arrives while there is still time to use it.
A graded collision-risk score over the window ahead, updated continuously rather than raised once at the moment of impact. It ramps as the danger develops, which is what makes it a warning rather than a report.
Zero-shot on platforms it has never seen. Forklifts, sidewalk robots, quadrupeds, drones, off-road vehicles. Same weights, no retraining, no platform-specific data.
What the model was looking at when it made the call, so a wrong answer can be diagnosed rather than argued about.
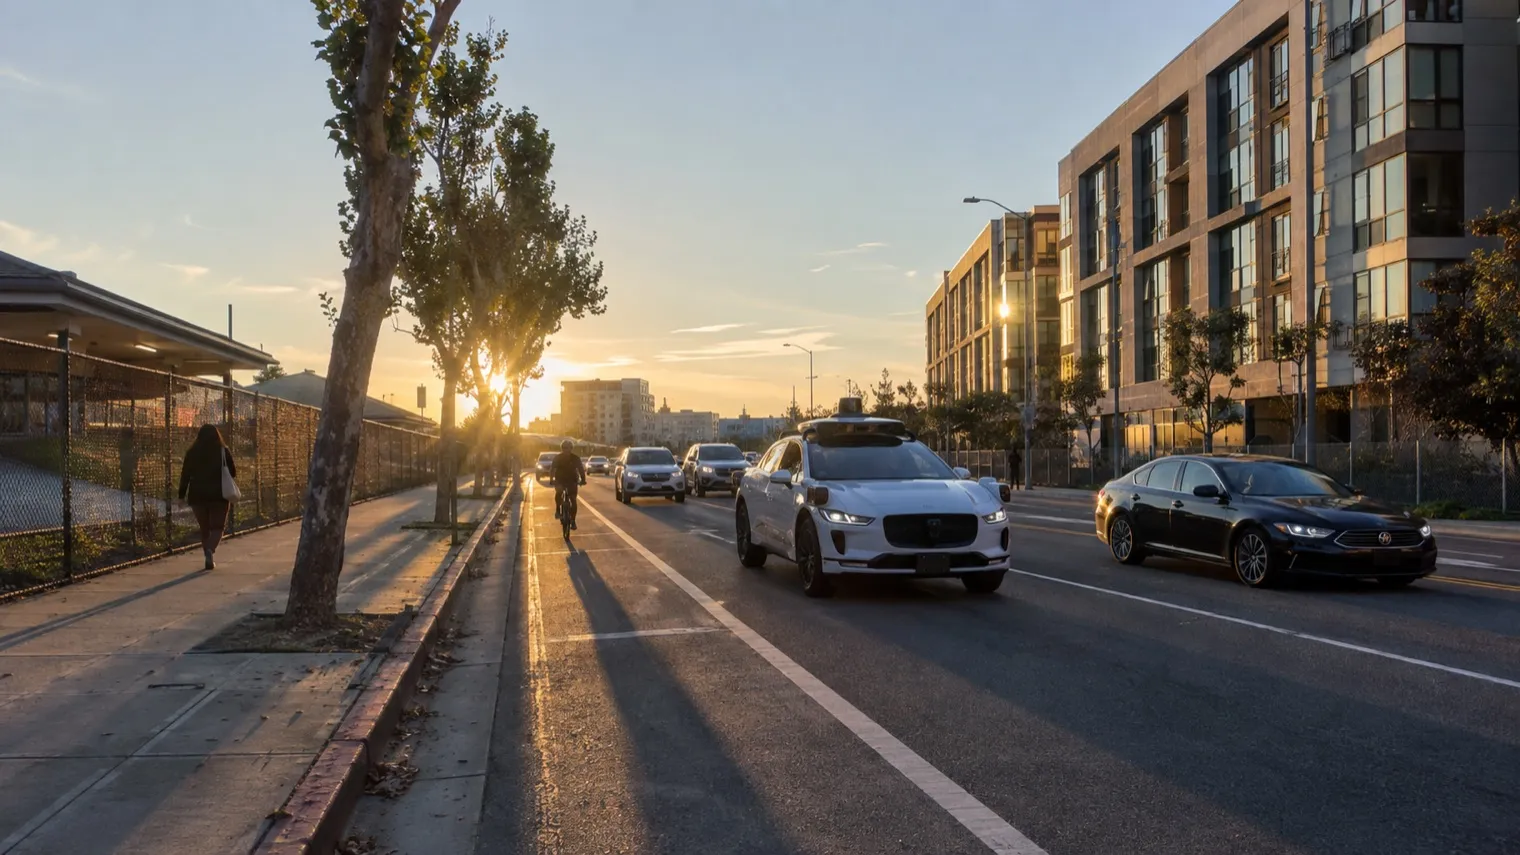 [ Observed · complex road state ]
Earlier
Prediction layer · inspectable
01 · AV + Robotics teams
Use real road behaviour to test systems against the rare, consequential states that average datasets smooth away.
Observed events Weighted by risk Ready for validation
Explore the evidence[ Observed · single video stream ]Edge
Jetson Thor-class · no round trip
02 · OEM + ADAS teams
Risk and attention from one forward pass on a single video stream, at the edge, so features inherit foresight instead of rules.
One video stream Under 3 ms per window Runs at the edge
Explore the evidence[ Observed · risk over the next window ]Sooner
Risk before the event
03 · Fleet safety teams
A collision-risk score over the coming seconds, predicted together with motion, so alerts fire on what is about to happen rather than what already did.
Risk and motion together Scored per window Inspectable
Explore the evidence[ Observed · near-miss behaviour ]Evidence
Observed · not assumed
04 · Insurance teams
Observed near-miss behaviour, ranked by risk, gives underwriting and claims a record of exposure instead of an assumption.
Observed events Ranked by risk Defensible
Explore the evidence[ Observed · real driving only ]Evidence
Published harness
05 · Research teams
Trained entirely on real driving with zero synthetic frames, and measured in a single harness against a frontier model many times its size, with the failure cases published alongside the wins.
Zero synthetic frames Published harness Long-tail benchmark
Explore the evidenceClosed-loop control is not part of this. BADAS 2.0 predicts and evaluates; what a system does with that is yours to build.
Upload a clip and watch what it predicts. Any forward-facing video stream, on anything that moves.
average precision across ten long-tail categories
false-alarm rate at that precision
smaller than the frontier model it is measured against
A single harness on identical hardware. Long-tail results are scored over 888 clips across ten scenario groups on a sliding window; the single-window benchmark is 1,344 clips scored at three warning lead times; public benchmarks are reported separately and never merged into one figure. Category definitions are fixed before the run. Failure cases are published with the wins.
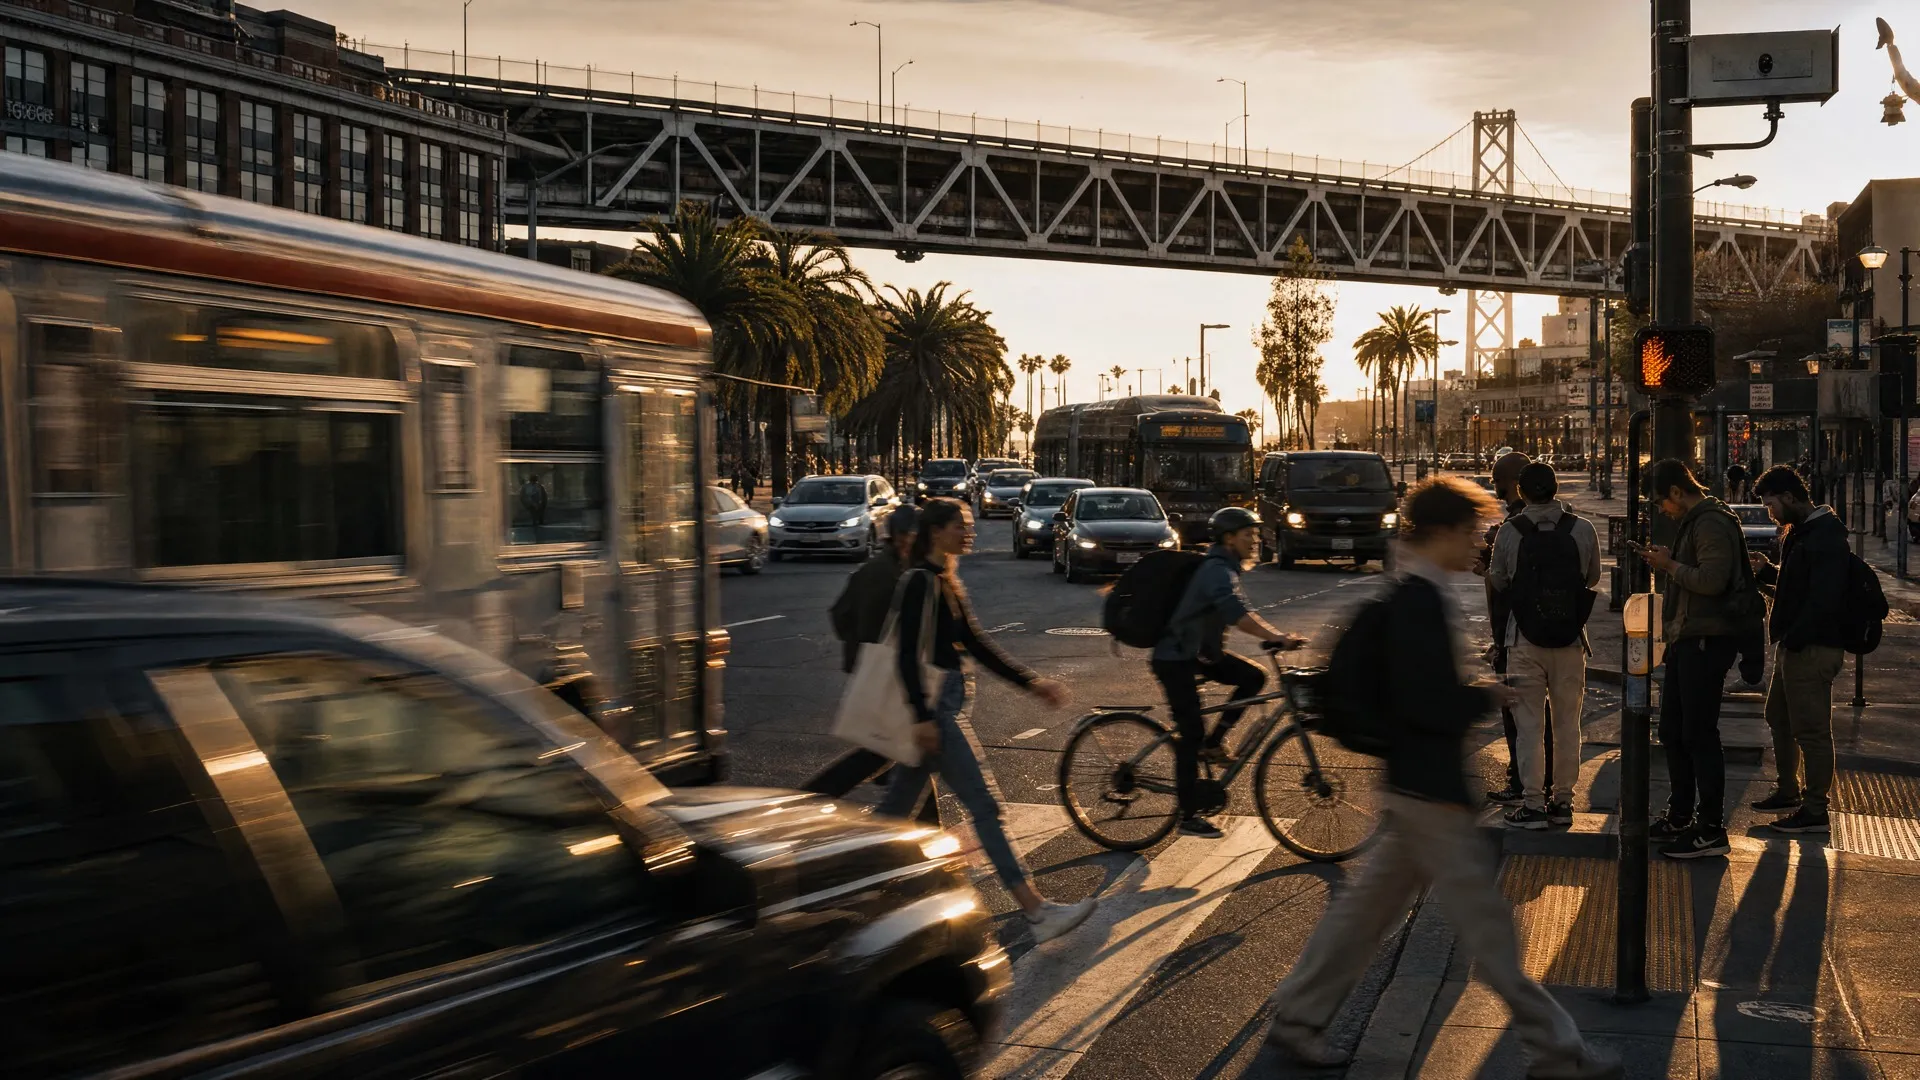
Trained entirely on real driving with zero synthetic frames, BADAS 2.0 reads scenes from outside that domain zero-shot. It did not learn a set of road rules, it learned how things in motion behave, which is why it holds up on scenes that look nothing like its training set.

300M (BADAS 2.0), 86M (Flash) and 22M (Flash Lite), against 2,000M for the frontier model it is measured against

Under 3 ms per two-second window on an NVIDIA A100, 5.9 ms on Jetson Thor

One video stream. No sensor rig, no calibration, no fusion stack

Runs at the edge on Jetson Thor-class hardware, no connectivity and no round trip

A graded collision-risk score per window, and an attention map showing what drove it
Typically answered in 1–2 business days
Typically replies in 1–2 business days.